Robotic inspection in simulation
Summary
A prototype for automated part handling and quality inspection.
The team needed to model a robot inspection workflow, scan a rotating part and compare its geometry with a nominal reference.
An Onshape-to-Isaac Sim workflow preserving robot joints and physics, with simulated LiDAR scans, point-cloud processing and geometric comparison.
Tech Challenge
-
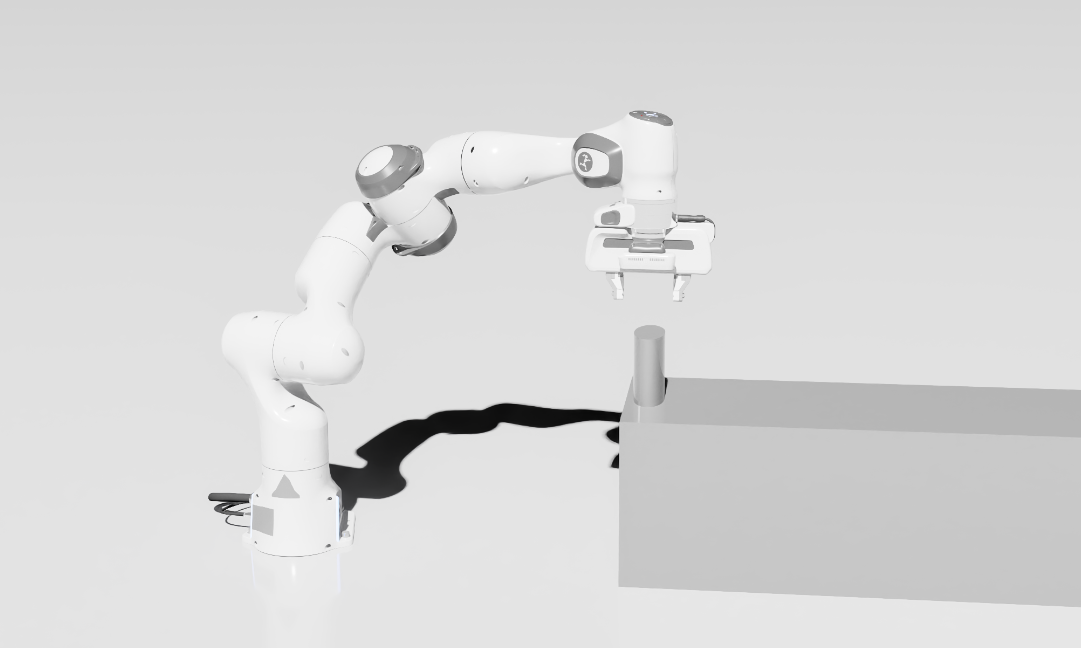
The first issue for DataRoot Labs was to bring the client’s robot prototype into Isaac Sim and keep its differentials, such as dynamic joints and physical properties. Apart from this, it was essential to set up a hyper-realistic scene and code the flow of imitation with great care. This setup should ensure that each robot goes through every step by specified instructions.
-
Efficient part point cloud comparison involved isolating Inspected components from other objects in the point cloud, especially the vise that holds them while rotating. Additionally, all noises from the sensor that originated from the LiDAR device have to be cleared away. The resultant scan comparisons should be vivid enough so that any deformity could be detected at a glance.
Tech Stack
- C++
- CUDA
- Python
- Nvidia Omniverse
- CloudCompare
Project workstreams
- 01
1 week
Solution Architecture Design
Solution ArchitectOmniverse Setup
Machine Learning Engieener - 02
3 weeks
Cloud Comparison Algorithm
Machine Learning Engineer - 03
3 weeks
Motion Planning Algorithm
Machine Learning Engineer - 04
1 week
Testing & Documentation
Machine Learning Engineer
Solution
- The robot prototype was imported into NVIDIA Omniverse Isaac Sim to model interactions before physical implementation. Joint structure and physical properties were preserved for the simulated workflow.
- One factory-made part is picked up by one robot and put into a vise held by another robot. After that, the vise closes around the detail and rotates, while the LiDAR sensor scans it. The rotation aims to capture all dimensions and features on the part with a 3D point cloud.
- We process the point cloud data using CloudCompy, a tool based on CloudCompare to separate the vise from all other parts of the point cloud so that only the part itself remains focused upon without its surrounding.
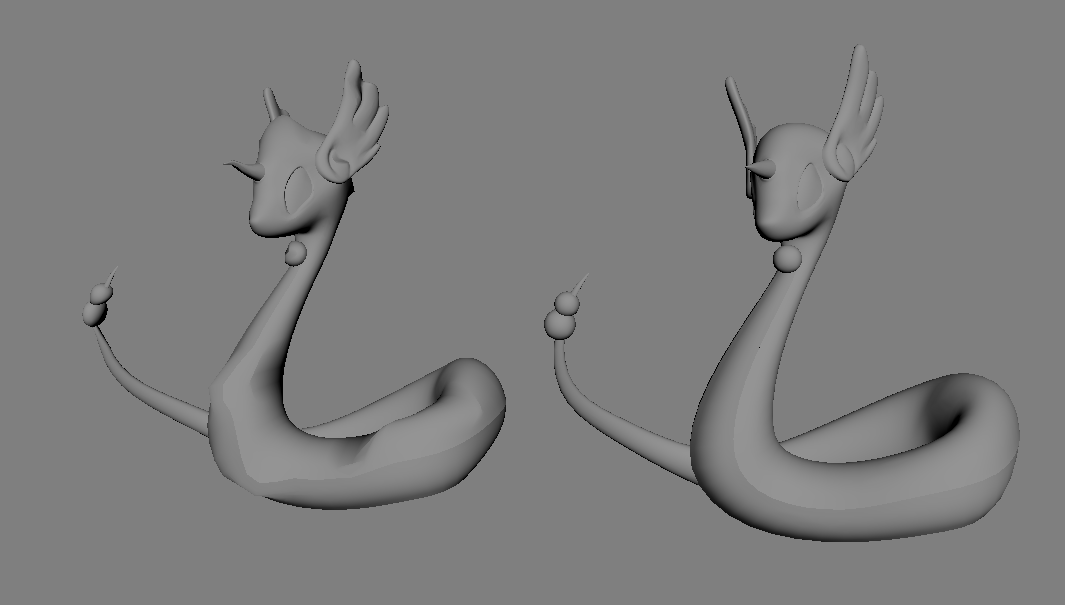
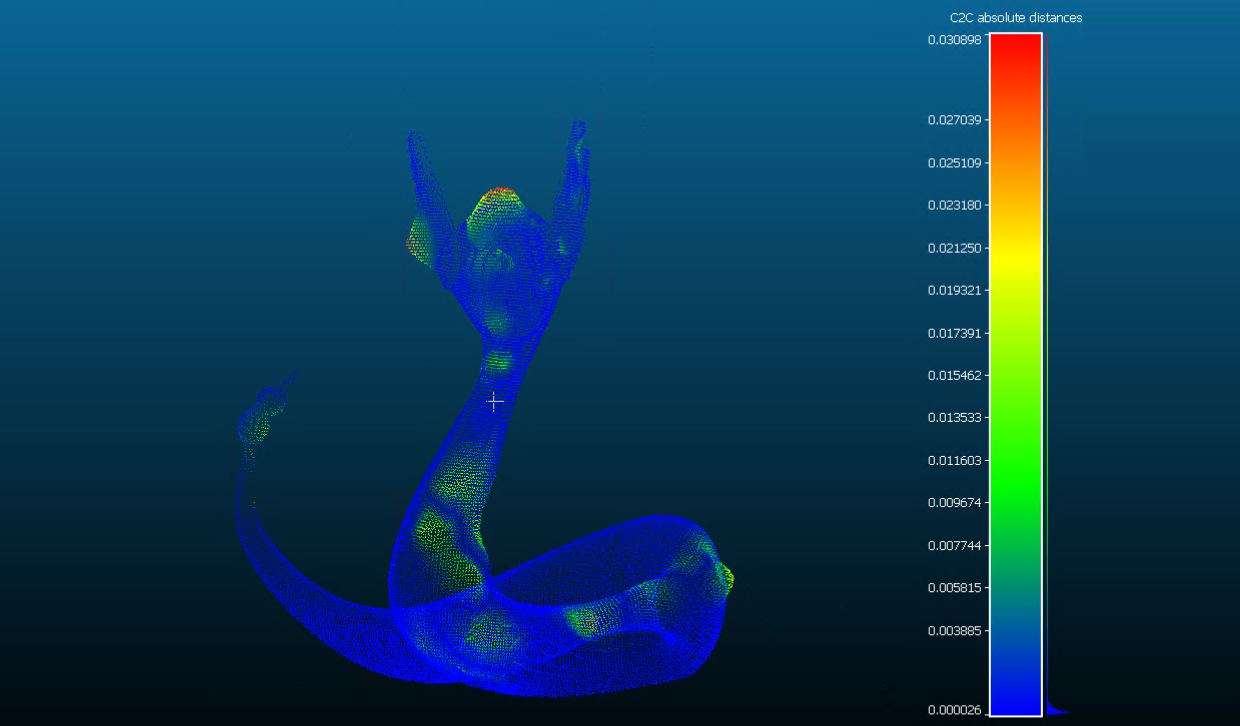
- The processed point cloud is compared with reference geometry to visualise deviations. The prototype visualises geometric differences for inspection.
Outcome
A simulated inspection prototype connecting robot handling, scanning and deviation analysis.
The work connected simulated robot handling, scanning and point-cloud comparison within NVIDIA Isaac Sim.
Published